
This is an old revision of the document!
Table of Contents
MPAINO-48A48T
MPAINO Series is an assembled industrial Arduino combining a CPU module with digital input and output modules.
Analog input/output, temperature sensor input, and high-speed pulse output modules can be added as options.
The selected I/O and optional modules are assembled and shipped as one product. Users cannot add or remove modules.
X analog input module details — DIP settings, wiring and examples → F PT100 input details — wiring, channels and example → Y analog output details — DIP settings, wiring and example → K pulse output details — channels, Timers and examples →
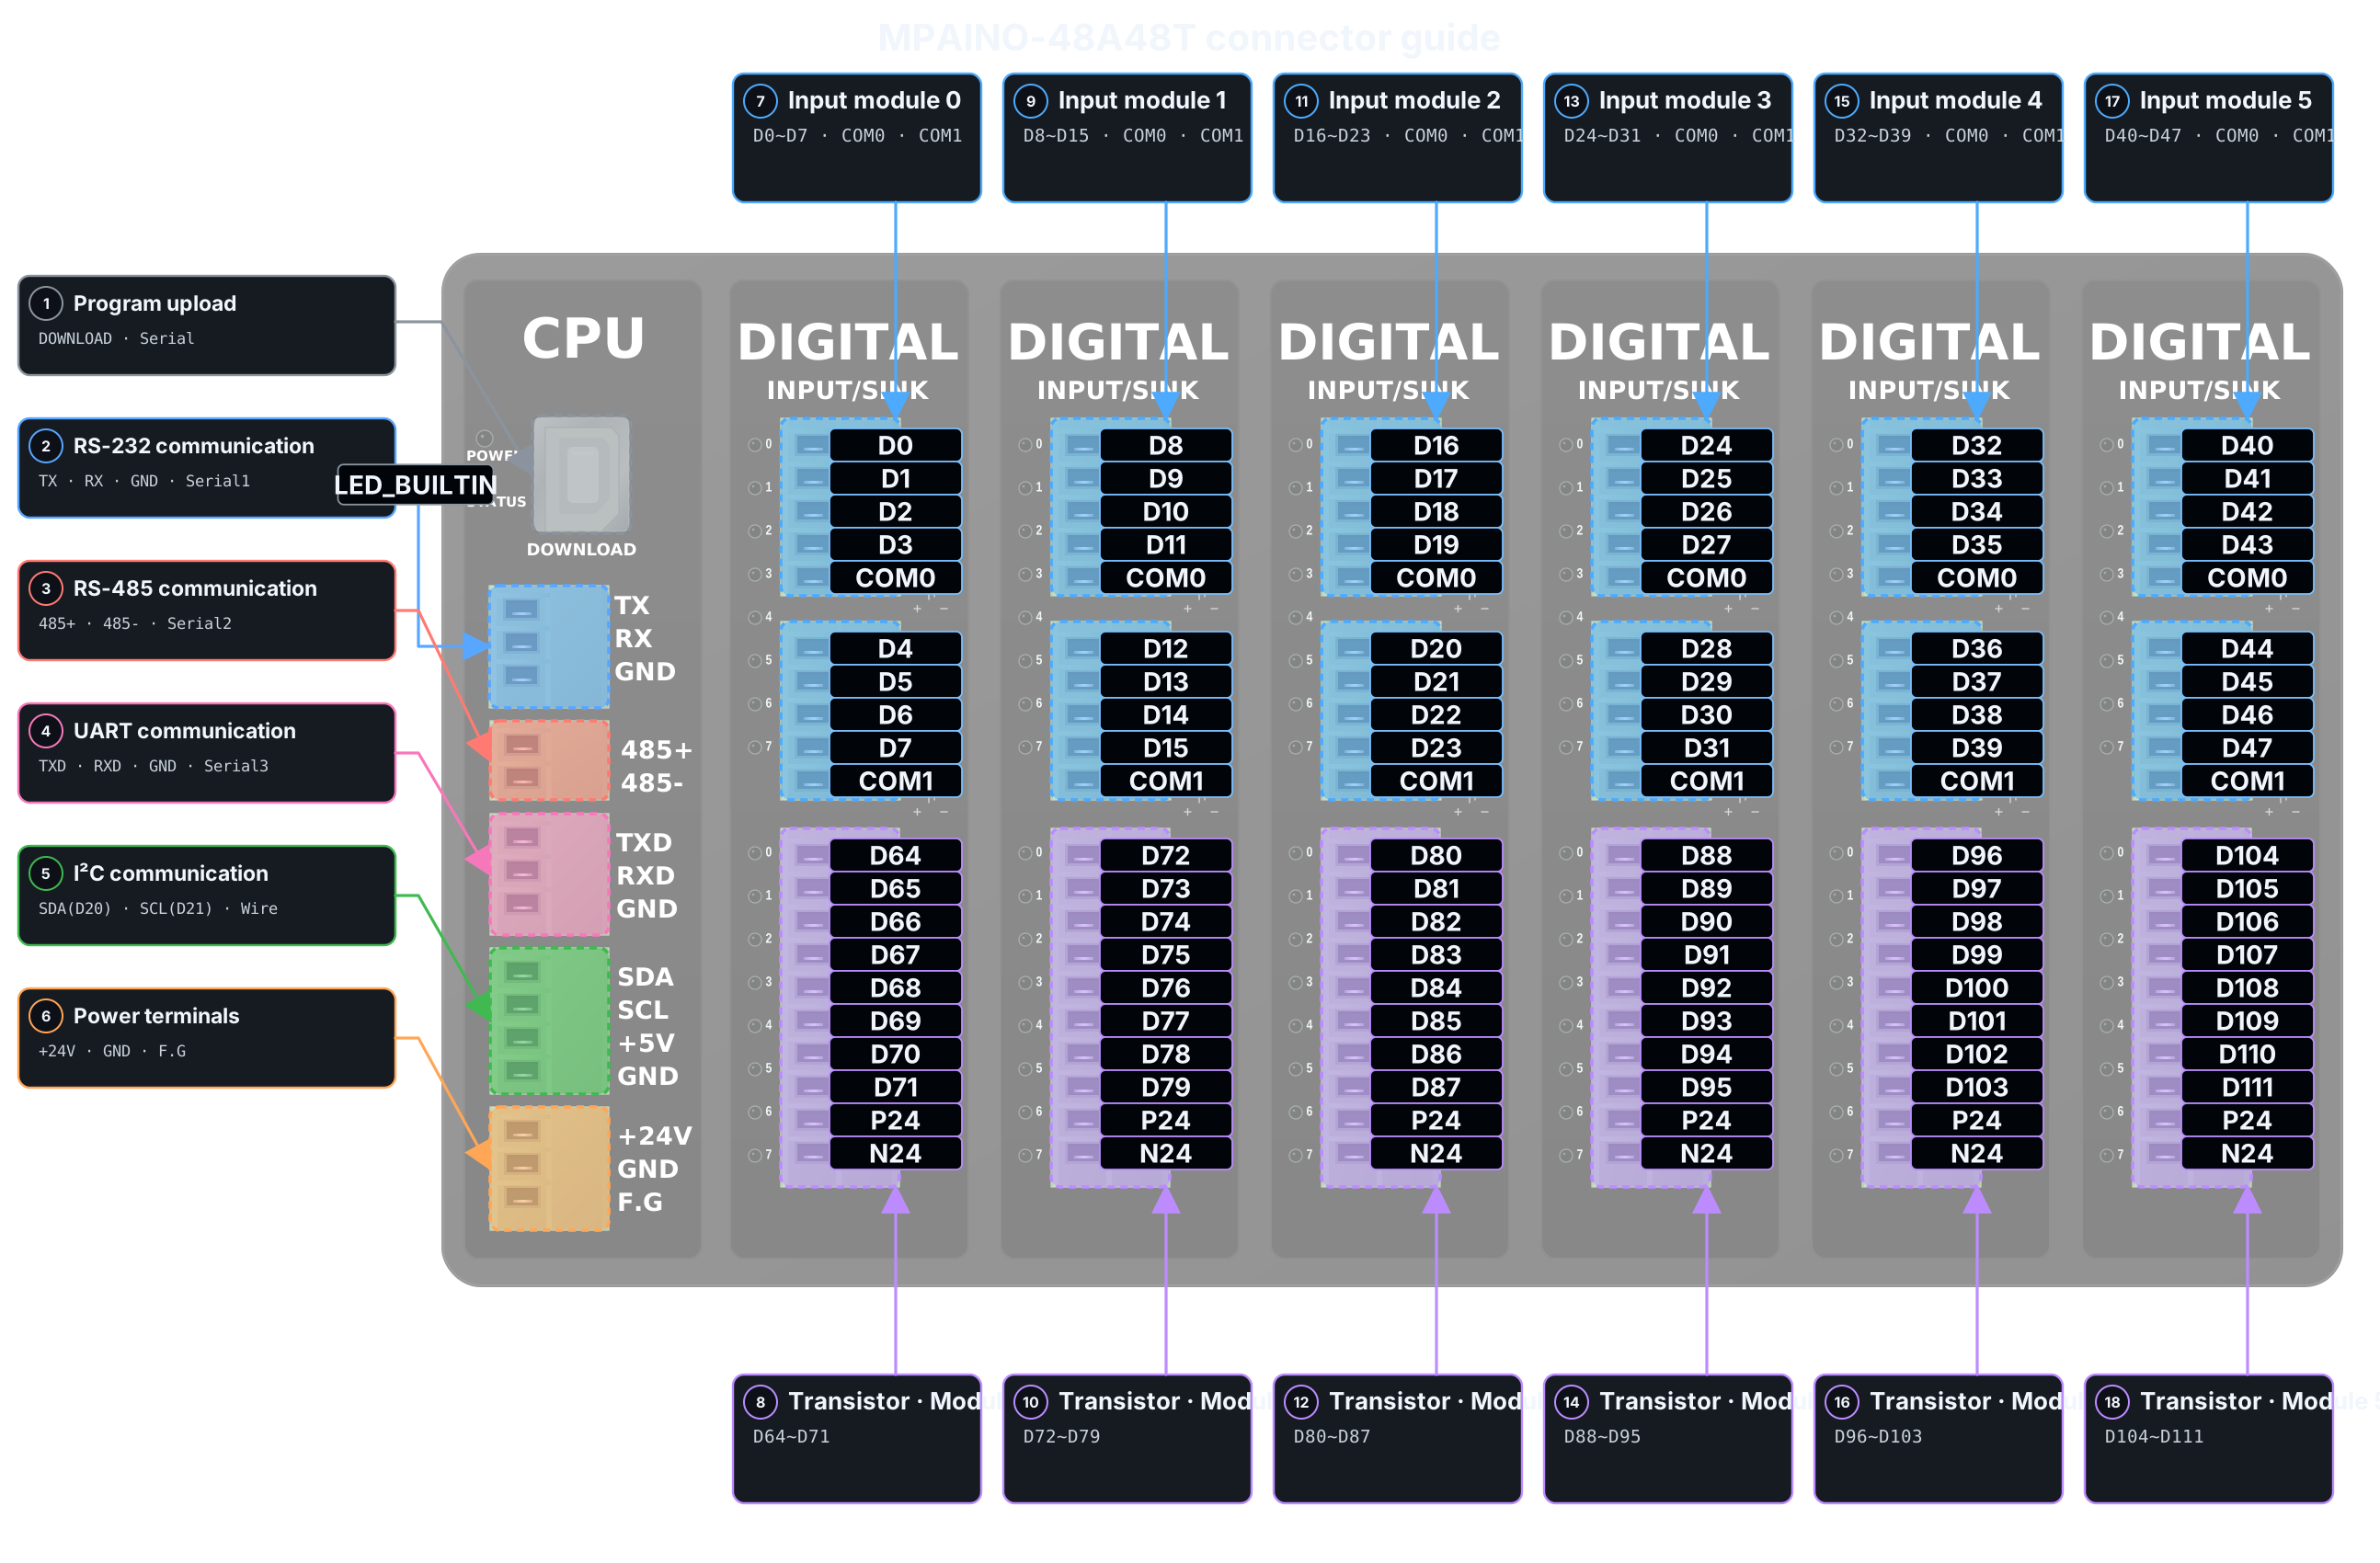
MPAINO-48A48T provides 48 digital inputs and 48 SINK transistor outputs.
Program the controller with Arduino IDE (Arduino C/C++) or MPINO STUDIO 2 (Arduino C/C++ & ladder logic).
Use the MPAINO-48A48T Arduino IDE getting-started guide to select the board and port and check the first input and output.
Product Specifications
| Category | Quantity | Terminal / Item | Specifications |
|---|---|---|---|
| Board | - | - | ATmega2560 Arduino Mega 2560 compatible |
| Power | - | Supply voltage | DC 12~24V For DC 24V, a power supply rated 0.5A or more is recommended |
| Digital inputs | 48 points (Isolated) | Module 0: D0~D7 Module 1: D8~D15 Module 2: D16~D23 Module 3: D24~D31 Module 4: D32~D39 Module 5: D40~D47 | operating input voltage: DC 0~40V HIGH detection voltage: DC 5V or higher 4 points/1COM NPN/PNP input support |
| Transistor outputs | 48 points (Isolated SINK) | Module 0: D64~D71 Module 1: D72~D79 Module 2: D80~D87 Module 3: D88~D95 Module 4: D96~D103 Module 5: D104~D111 | P24 input voltage: DC 5~24V load voltage: DC 0~100V maximum allowable current: 1A/1 points, 8A/1COM 8 points/1COM |
| 2 points (Non-isolated) | SDA(D20·INT2), SCL(D21·INT3) | Max. 50kHz Built-in 4.7kΩ pull-up Shared with I²C communication |
|
| Communication Channels | 1 channel (Non-isolated) | I²C | SDA(D20), SCL(D21) Use Wire |
| RS-232 | Use Serial1 |
||
| RS-485 | Use Serial2 |
||
| UART | CPU module TXD/RXD terminals Use Serial3 |
||
| Memory | - | Flash | 256KB |
| SRAM | 8KB | ||
| EEPROM | 4KB |
Digital inputs
| Module | Group | Terminal | Input Configuration | Terminals and Wiring Example |
|---|---|---|---|---|
| Module 0 | COM0 COM1 | D0~D3 D4~D7 | 8 isolated digital inputs |  |
| Module 1 | COM0 COM1 | D8~D11 D12~D15 | 8 isolated digital inputs | |
| Module 2 | COM0 COM1 | D16~D19 D20~D23 | 8 isolated digital inputs | |
| Module 3 | COM0 COM1 | D24~D27 D28~D31 | 8 isolated digital inputs | |
| Module 4 | COM0 COM1 | D32~D35 D36~D39 | 8 isolated digital inputs | |
| Module 5 | COM0 COM1 | D40~D43 D44~D47 | 8 isolated digital inputs |
The digital inputs are isolated by optocouplers and accept DC 5~24V NPN or PNP switches and sensors. Select the input type through the COM terminal wiring polarity of each module.
- If the input terminal receives DC 5~24V, connect the corresponding COM to GND.
- If the input terminal receives GND, connect the corresponding COM to DC 5~24V.
Example program · digital inputs
Read the states of input logical numbers 0~47 with digitalRead(). The current ILOGICS core internally translates the original physical D numbers printed on the terminals.
void setup() {
  Serial.begin(115200);
}

void loop() {
  for (uint8_t ch = 0; ch < 48; ++ch) {
    Serial.print(ch);
    Serial.print(": " );
    Serial.println(digitalRead(ch));
  }
  delay(500);
}
Related built-in functions
Function example · consecutive-read filter: IdigitalRead()
Function prototype
bool IdigitalRead(uint8_t pin, uint8_t samples);
IdigitalRead(0, 5) reads input 0 5 times consecutively. Update the state when all readings are HIGH or all are LOW; mixed readings retain the previous state. Unlike a time-based debounce filter, it inserts no delay between readings.
void setup() {
  Serial.begin(115200);
}

void loop() {
  const bool inputOn = IdigitalRead(0, 5);  // Read input 0 five times consecutively and return the stable state
  Serial.println(inputOn ? F("Input 0 ON") : F("Input 0 OFF"));
  delay(200);
}
Function example · debouncing: Ibounce(), IbounceOn(), IbounceOff()
Function prototype
bool Ibounce(uint8_t pin, uint32_t debounceTime);
bool IbounceOn(uint8_t pin, uint32_t debounceTime);
bool IbounceOff(uint8_t pin, uint32_t debounceTime);
Compare three filters on input 0. The return value is the filtered ON/OFF state.
Ibounce(0, 30): Apply either ON or OFF after it remains stable for at least 30ms.IbounceOn(0, 500): Delay ON by 500ms; apply OFF immediately.IbounceOff(0, 500): Delay OFF by 500ms; apply ON immediately.
Each function operates independently, even on the same pin. Run the filters on every loop() iteration and display only the results at 200ms intervals.
unsigned long lastPrint = 0;

void setup() {
  Serial.begin(115200);
}

void loop() {
  const bool stable = Ibounce(0, 30);  // Filter input 0 ON/OFF chatter over 30ms
  const bool onDelayed = IbounceOn(0, 500);  // Delay only input 0 ON by 500ms; apply OFF immediately
  const bool offDelayed = IbounceOff(0, 500);  // Delay only input 0 OFF by 500ms; apply ON immediately

  if (millis() - lastPrint >= 200) {
    lastPrint = millis();
    Serial.print(F("Ibounce: "));
    Serial.print(stable);
    Serial.print(F(", IbounceOn: "));
    Serial.print(onDelayed);
    Serial.print(F(", IbounceOff: "));
    Serial.println(offDelayed);
  }
}
Function example · input toggle: Ialt()
Function prototype
void Ialt(bool input, bool &state_var);
Ialt(input, state) inverts state whenever the input changes from OFF to ON. Pressing input 0 once turns output 64 ON; pressing again turns it OFF. Holding the input retains the state. The example debounces the input with Ibounce(0, 30) before passing it to Ialt(). outputOn is a global variable retained between calls, and Ialt() modifies it directly.
bool outputOn = false;

void setup() {
  Serial.begin(115200);
  digitalWrite(64, LOW);
}

void loop() {
  const bool previous = outputOn;
  const bool inputOn = Ibounce(0, 30);  // Filter input 0 ON/OFF chatter over 30ms
  Ialt(inputOn, outputOn);  // Invert outputOn on an OFF→ON input transition
  digitalWrite(64, outputOn ? HIGH : LOW);

  if (outputOn != previous) {
    Serial.println(outputOn ? F("Output 64 ON") : F("Output 64 OFF"));
  }
}
Transistor outputs
| Module | Output terminals | Output power | Output configuration | Terminals and Wiring Example |
|---|---|---|---|---|
| Module 0 | D64~D71 | P24 N24 | 8 isolated SINK transistor outputs |  |
| Module 1 | D72~D79 | P24 N24 | 8 isolated SINK transistor outputs | |
| Module 2 | D80~D87 | P24 N24 | 8 isolated SINK transistor outputs | |
| Module 3 | D88~D95 | P24 N24 | 8 isolated SINK transistor outputs | |
| Module 4 | D96~D103 | P24 N24 | 8 isolated SINK transistor outputs | |
| Module 5 | D104~D111 | P24 N24 | 8 isolated SINK transistor outputs |
Connect a DC 5~24V supply to P24 on each module and connect its GND to N24. When ON, the selected output terminal is connected to the GND supplied at that module's N24.
| Item | Rating |
|---|---|
| Load voltage | DC 0~100V |
| Maximum allowable current | 1A/1 points |
| Maximum allowable current per module | 8A/1COM |
Example program · transistor outputs
Map inputs 0~47 to outputs 64~111. When HIGH, the SINK transistor output turns ON.
void setup() {
  for (uint8_t ch = 0; ch < 48; ++ch) digitalWrite(64 + ch, LOW);
}

void loop() {
  for (uint8_t ch = 0; ch < 48; ++ch) {
    digitalWrite(64 + ch, digitalRead(ch));
  }
}
Interrupts / High-speed inputs
| Terminal | Configuration | Maximum input frequency | Mutually exclusive functions | Encoder wiring |
|---|---|---|---|---|
| SDA(D20·INT2), SCL(D21·INT3) | Non-isolated input, built-in 4.7kΩ pull-up | 50kHz | I²C communication |  |
Connect the encoder with phase A on SDA(D20) and phase B on SCL(D21). When SDA·SCL are used as encoder or interrupt inputs, I²C communication cannot be used simultaneously on the same terminals.
Example program · pulse counting
SDA(D20) on the I²C terminals is a 4.7kΩ pull-up input. Do not use this example simultaneously with I²C communication. In the MPAINO board package, argument 2 of digitalPinToInterrupt() is the logical interrupt number assigned to SDA, not digital input 2. Count FALLING edges when SDA changes from HIGH to LOW. This is a software ISR example and does not guarantee lossless counting at the maximum frequency.
#include <util/atomic.h>

static_assert(digitalPinToInterrupt(2) == 3, "SDA interrupt mapping");
volatile uint32_t pulseCount = 0;
void onPulse() { ++pulseCount; }

void setup() {
  Serial.begin(115200);
  attachInterrupt(digitalPinToInterrupt(2), onPulse, FALLING);
}

void loop() {
  uint32_t count;
  ATOMIC_BLOCK(ATOMIC_RESTORESTATE) { count = pulseCount; }
  Serial.println(count);
  delay(500);
}
Example program · encoder inputs
SDA(D20) on the I²C terminals is a 4.7kΩ pull-up input. Do not use this example simultaneously with I²C communication. In the MPAINO board package, argument 2 of digitalPinToInterrupt() is the logical interrupt number assigned to SDA, not digital input 2. Connect phase A to SDA and phase B to SCL. At the falling edge of phase A, increment when B is HIGH and decrement when B is LOW. The direction changes with the phase A/B connections. Because SCL overlaps the digital module logical numbers, read the physical pin state directly.
#include <util/atomic.h>

static_assert(digitalPinToInterrupt(2) == 3, "SDA interrupt mapping");
volatile int32_t position = 0;

void onEncoder() {
  // Read the physical SCL pin directly because its number overlaps a digital module logical number
  const bool bHigh = (*portInputRegister(digitalPinToPort(SCL)) & digitalPinToBitMask(SCL)) != 0;
  if (bHigh) ++position;
  else --position;
}

void setup() {
  Serial.begin(115200);
  attachInterrupt(digitalPinToInterrupt(2), onEncoder, FALLING);
}

void loop() {
  int32_t value;
  ATOMIC_BLOCK(ATOMIC_RESTORESTATE) { value = position; }
  Serial.println(value);
  delay(500);
}
Communication and program upload
| Function | Arduino object | Terminals / Pins | Device Wiring |
|---|---|---|---|
| Program upload and monitoring | Serial | Download port |  |
| RS-232 | Serial1 | CPU module RS-232 terminals | |
| RS-485 | Serial2 | CPU module RS-485 terminals | |
| UART | Serial3 | CPU module TXD/RXD terminals | |
| I²C | Wire | SDA: D20, SCL: D21 |
The RS-232, RS-485, and UART channels support the built-in Modbus RTU Master/Slave and LS Industrial Systems Cnet functions.
Example program · basic communication
Forward characters between Serial(115200bps) and RS-232(Serial1, 9600bps, 8N1). Run each port example independently.
// Serial Monitor via USB download port ↔ RS-232 Serial1
void setup() {
  Serial.begin(115200);
  Serial1.begin(9600);  // Also configure the other device for 9600 bps, 8-N-1
}

void loop() {
  if (Serial.available() && Serial1.availableForWrite()) {
    Serial1.write(Serial.read());
  }
  if (Serial1.available() && Serial.availableForWrite()) {
    Serial.write(Serial1.read());
  }
}
Forward characters between Serial(115200bps) and RS-485(Serial2, 9600bps, 8N1). Run each port example independently.
// USB download port Serial Monitor ↔ RS-485 Serial2
void setup() {
  Serial.begin(115200);
  Serial2.begin(9600);  // Also configure the other device for 9600 bps, 8-N-1
}

void loop() {
  if (Serial.available() && Serial2.availableForWrite()) {
    Serial2.write(Serial.read());
  }
  if (Serial2.available() && Serial.availableForWrite()) {
    Serial.write(Serial2.read());
  }
}
Forward characters between Serial(115200bps) and UART(Serial3, 9600bps, 8N1). Run each port example independently.
// USB download port Serial Monitor ↔ UART Serial3
void setup() {
  Serial.begin(115200);
  Serial3.begin(9600);  // Also configure the other device for 9600 bps, 8-N-1
}

void loop() {
  if (Serial.available() && Serial3.availableForWrite()) {
    Serial3.write(Serial.read());
  }
  if (Serial3.available() && Serial.availableForWrite()) {
    Serial.write(Serial3.read());
  }
}
Example program · I²C communication
Scan for I²C device addresses on SDA·SCL. Do not run this simultaneously with pulse/encoder examples that use the same terminals.
#include <Wire.h>

void setup() {
  Serial.begin(115200);
  Wire.begin();
  Wire.setClock(100000);
}

void loop() {
  uint8_t found = 0;
  for (uint8_t address = 0x08; address <= 0x77; address++) {
    Wire.beginTransmission(address);
    const uint8_t result = Wire.endTransmission();
    if (result == 0) {
      Serial.print(F("I2C: 0x"));
      if (address < 16) Serial.print('0');
      Serial.println(address, HEX);
      found++;
    }
  }
  Serial.print(F("Devices: "));
  Serial.println(found);
  delay(3000);
}
Example program · Modbus RTU communication
Related built-in functions
Function example · Modbus RTU Slave: ImodbusRTUMem(), ImodbusRTUAdr(), ImodbusRTUInit(), ImodbusRTU()
Function prototype
void ImodbusRTUMem(uint16_t m_size, uint16_t d_size);
void ImodbusRTUAdr(uint16_t m_offset, uint16_t d_offset);
void ImodbusRTUInit(HardwareSerial& serialPort, uint8_t slaveId, long baudrate);
void ImodbusRTU();
Store input 0 in M[0] and operating time (seconds) in D[0] for the other device to read. Configure RS-485(Serial2), station 1, 9600bps, 8N1. Read M[0] with FC01, start address 0, 1 bit; read D[0] with FC03, start address 0, 1 word. Addresses are actual transmitted addresses, starting from 0. Call the communication function on every loop() iteration; this example does not control outputs.
M and D are shared global memory provided by the core. Run this sketch on its own. When combining protocols, do not allocate the shared memory more than once.
unsigned long lastPrint = 0;
bool memoryReady = false;

void setup() {
  Serial.begin(115200);
  ImodbusRTUMem(8, 8);  // Allocate 8 M bits and 8 D words
  ImodbusRTUAdr(0, 0);  // Set the M and D communication start addresses to 0
  ImodbusRTUInit(Serial2, 1, 9600);  // Start RS-485 at station 1, 9600bps
  memoryReady = (M != nullptr && D != nullptr);
  if (!memoryReady) Serial.println(F("Memory allocation failed"));
}

void loop() {
  if (!memoryReady) return;
  M[0] = digitalRead(0);
  D[0] = (uint16_t)(millis() / 1000UL);
  ImodbusRTU();  // Process incoming Modbus RTU requests

  if (millis() - lastPrint >= 1000) {
    lastPrint = millis();
    Serial.print(F("M[0]: "));
    Serial.print(M[0]);
    Serial.print(F(", D[0]: "));
    Serial.println(D[0]);
  }
}
Function example · Modbus RTU Master: ImodbusRTUmasterInit(), ImodbusRTUmaster()
Function prototype
void ImodbusRTUmasterInit(HardwareSerial& serialPort, long baudrate, uint8_t config);
uint8_t ImodbusRTUmaster(HardwareSerial& serialPort, uint8_t slaveId, uint8_t functionCode, uint16_t address, uint16_t quantity, uint16_t* data, uint16_t timeoutMs = 100);
Read 1 holding register from the slave every 1 second over RS-485(Serial2). Configure the other device for station 1, 9600bps, 8N1, FC03, and on-wire start address 0. The response is stored in received[0] and displayed only on success. Error codes are displayed in hexadecimal. This is a separate sketch from the slave example above and uses a receive array instead of M/D memory.
unsigned long lastRequest = 0;
uint16_t received[1];

void setup() {
  Serial.begin(115200);
  ImodbusRTUmasterInit(Serial2, 9600, SERIAL_8N1);  // Start RS-485 as a Modbus master
}

void loop() {
  if (millis() - lastRequest < 1000) return;
  lastRequest = millis();
  const uint8_t result = ImodbusRTUmaster(Serial2, 1, 3, 0, 1, received, 200);  // Read 1 word at address 0 from station 1, timeout 200ms

  if (result == IMODBUS_RTU_SUCCESS) {
    Serial.print(F("Register 0: "));
    Serial.println(received[0]);
  } else {
    Serial.print(F("Modbus error: 0x"));
    Serial.println(result, HEX);
  }
}
Example program · LS Industrial Systems Cnet communication
Related built-in functions
Function example · LS Industrial Systems Cnet SLave: ICnetMem(), ICnetAdr(), ICnetInit(), ICnet()
Function prototype
void ICnetMem(uint16_t m_size, uint16_t d_size, uint16_t r_size = 100);
void ICnetAdr(uint16_t m_offset, uint16_t d_offset, uint16_t r_offset = 0);
void ICnetInit(HardwareSerial& serialPort, uint8_t slaveId, long baudrate);
void ICnet();
Store input 0 in M[0] and operating time (seconds) in D[0] for the HMI to read. Configure the other device for LS Industrial Systems Cnet, RS-232, station 1, 9600bps, 8N1. Read %MX00000(M[0]) for the bit and %DW0(D[0]) for the word. Call the communication function on every loop() iteration; this example does not control outputs.
M, D, and R are shared global memory provided by the core; this example does not use R. Run this separately from the Modbus example. When combining protocols, do not allocate the shared memory more than once.
unsigned long lastPrint = 0;
bool memoryReady = false;

void setup() {
  Serial.begin(115200);
  ICnetMem(8, 8, 0);  // Allocate 8 M bits and 8 D words; R is unused
  ICnetAdr(0, 0, 0);  // Set the M and D communication start addresses to 0
  ICnetInit(Serial1, 1, 9600);  // Start RS-232 at station 1, 9600bps
  memoryReady = (M != nullptr && D != nullptr);
  if (!memoryReady) Serial.println(F("Memory allocation failed"));
}

void loop() {
  if (!memoryReady) return;
  M[0] = digitalRead(0);
  D[0] = (uint16_t)(millis() / 1000UL);
  ICnet();  // Process incoming LS Cnet requests

  if (millis() - lastPrint >= 1000) {
    lastPrint = millis();
    Serial.print(F("M[0]: "));
    Serial.print(M[0]);
    Serial.print(F(", D[0]: "));
    Serial.println(D[0]);
  }
}
Optional modules
This example is for a product shipped with the corresponding optional module. Match the module configuration shown in the example to the actual factory configuration.
Example program · analog inputs (with X module installed)
This configuration has 1 installed X module with Analog Input Module → X selected. analogRead(0~3) reads the ADS1118 raw values (0~32767) from the first X module. Match each channel's DIP settings and wiring to its input signal.
void setup() {
  Serial.begin(115200);
}

void loop() {
  for (uint8_t ch = 0; ch < 4; ++ch) {
    Serial.print(ch);
    Serial.print(": " );
    Serial.println(analogRead(ch));
  }
  delay(500);
}
Related built-in functions
Function example · input range scaling: IanalogRead(), IanalogReadf()
Function prototype
int32_t IanalogRead(uint8_t ch, int32_t min, int32_t max);
float IanalogReadf(uint8_t ch, float min, float max);
This example configures X module channel 0 for 0~5V and channel 1 for current input. Both functions scale the ADC input to the specified min~max range. IanalogRead() returns an integer with the fractional part discarded; IanalogReadf() returns a floating-point value. Display the 0~5V input on channel 0 as both 0~100% and voltage. For the 0~20mA input on channel 1, specify the range 0~20 to read the actual current.
void setup() {
  Serial.begin(115200);
}

void loop() {
  const int32_t percent = IanalogRead(0, 0, 100);  // Scale input 0 to an integer from 0~100%
  const float voltage = IanalogReadf(0, 0.0f, 5.0f);  // Scale input 0 to a floating-point value from 0~5V
  const float current = IanalogReadf(1, 0.0f, 20.0f);  // Scale input 1 to a floating-point value from 0~20mA
  Serial.print(F("0: "));
  Serial.print(percent);
  Serial.print(F(" %, "));
  Serial.print(voltage, 2);
  Serial.print(F(" V, 1: "));
  Serial.print(current, 2);
  Serial.println(F(" mA"));
  delay(500);
}
Function example · 4~20mA range scaling: IanalogRead2(), IanalogRead2f()
Function prototype
int32_t IanalogRead2(uint8_t ch, int32_t min, int32_t max);
float IanalogRead2f(uint8_t ch, float min, float max);
This example configures X module channel 0 for 0~5V and channel 1 for current input. Scale the 4~20mA sensor input connected to channel 1 to a user-defined range. IanalogRead2(channel 1, 0, 100) returns an integer mapping 4mA to 0% and 20mA to 100%. IanalogRead2f(channel 1, 4.0f, 20.0f) returns the current as a floating-point value. Below approximately 3.6mA, both functions return ANALOG_READ2_ERROR(65535); from approximately 3.6~4mA, they return the specified minimum.
void setup() {
  Serial.begin(115200);
}

void loop() {
  const int32_t percent = IanalogRead2(1, 0, 100);  // Scale input 1 at 4~20mA to an integer from 0~100%
  const float current = IanalogRead2f(1, 4.0f, 20.0f);  // Convert input 1 at 4~20mA to a floating-point current value
  if (percent == ANALOG_READ2_ERROR ||
      current == (float)ANALOG_READ2_ERROR) {
    Serial.println(F("1: 4-20mA input error"));
  } else {
    Serial.print(F("1: "));
    Serial.print(percent);
    Serial.print(F(" %, "));
    Serial.print(current, 2);
    Serial.println(F(" mA"));
  }
  delay(500);
}
Function example · moving average: analogReadAvg(), analogRead2Avg()
Function prototype
int32_t analogReadAvg(uint8_t ch, uint8_t samples);
int32_t analogRead2Avg(uint8_t ch, uint8_t samples);
This example configures X module channel 0 for 0~5V and channel 1 for current input. analogReadAvg(channel 0, 5) returns a moving average of channel 0 ADC raw values (0~32767); analogRead2Avg(channel 1, 5) returns a moving average of channel 1 4~20mA corrected values (4mA=0, 20mA=32767). It averages up to 5 valid values from recent calls; it does not perform 5 reads in one call. The maximum samples value is 20. analogRead2Avg() returns ANALOG_READ2_AVG_ERROR(-1) for inputs below approximately 3.6mA.
void setup() {
  Serial.begin(115200);
}

void loop() {
  const int32_t voltageAvg = analogReadAvg(0, 5);  // Moving average of up to 5 recent ADC values from input 0
  const int32_t currentAvg = analogRead2Avg(1, 5);  // Moving average of up to 5 recent 4~20mA-adjusted values from input 1
  Serial.print(F("0 ADC average: "));
  Serial.print(voltageAvg);
  Serial.print(F(", 1 4-20mA average: "));
  if (currentAvg == ANALOG_READ2_AVG_ERROR) {
    Serial.println(F("input error"));
  } else {
    Serial.println(currentAvg);
  }
  delay(500);
}
Example program · NTC temperature sensor inputs (with X module installed)
With 1 X module and Analog Input Module → X selected, configure channel 0 for NTC mode. First check the raw value with analogRead(0).
void setup() {
  Serial.begin(115200);
}

void loop() {
  Serial.println(analogRead(0));
  delay(500);
}
Related built-in functions
Function example · NTC temperature conversion: ntcRead(), ntcReadf()
Function prototype
int ntcRead(uint8_t ch);
float ntcReadf(uint8_t ch);
Configure X module channel 0 for NTC mode and connect an NTC 3950 10kΩ sensor. ntcRead() returns temperature in Celsius ×10 as an integer; ntcReadf() returns floating-point degrees Celsius. Out-of-range inputs are limited to the endpoints of -40~120°C, so do not use this as an open-circuit detection function.
void setup() {
  Serial.begin(115200);
}

void loop() {
  const int temp10 = ntcRead(0);  // X channel 0 temperature in Celsius ×10
  const float tempC = ntcReadf(0);  // X channel 0 temperature as floating-point Celsius
  Serial.print(temp10);
  Serial.print(", " );
  Serial.println(tempC, 1);
  delay(500);
}
Example program · PT100 temperature sensor inputs (with F module installed)
Related built-in functions
Function example · read PT100 input: pt100Read()
Function prototype
int pt100Read(uint8_t ch);
Install 1 F module and select Temperature Sensor Input Module → F. 0~3 are the channels of the first F module. Display the input values of F module channels 0~3 in the Serial Monitor.
void setup() {
  Serial.begin(115200);
}

void loop() {
  for (uint8_t ch = 0; ch < 4; ++ch) {
    const int value = pt100Read(ch);  // Read the corresponding F module channel input
    Serial.print(ch);
    Serial.print(": " );
    Serial.println(value);
  }
  delay(500);
}
Example program · analog outputs (with Y module installed)
Install 1 Y module and select Analog Output Module → Y. The value in analogWrite(0~2, value) ranges from 0~65535. Output the midpoint value 32768 on channel 0; the output voltage/current range follows the module DIP settings.
void setup() {

}

void loop() {
  analogWrite(0, 32768);
  delay(500);
}
Related built-in functions
Function example · output range scaling: IanalogWrite(), IanalogWritef()
Function prototype
void IanalogWrite(uint8_t ch, int32_t min, int32_t max, int32_t value);
void IanalogWritef(uint8_t ch, float min, float max, float value);
Output 50% using an integer value on Y module channel 0 and 25% using a floating-point value on channel 1. min·max define the user-value range; the module DIP switches determine the electrical output mode.
void setup() {

}

void loop() {
  IanalogWrite(0, 0, 100, 50);  // Output 50% on Y channel 0
  IanalogWritef(1, 0.0f, 100.0f, 25.0f);  // Output 25% on Y channel 1
  delay(500);
}
Example program · PWM outputs (with K module installed)
Install 1 K module, select High-Speed Pulse Output Module → K, and set Y module to None. Use 20~25 for Arduino analogWrite(), 0~5 for the built-in PWM functions, and 130~135 for GPIO control. Output approximately 50% duty on the first K output.
void setup() {

}

void loop() {
  analogWrite(20, 128);
  delay(500);
}
Related built-in functions
Function example · specify duty value: PWM()
Function prototype
void PWM(uint8_t pin, uint16_t val, bool onDutybit16 = false);
The configuration is 1 K module, no Y module, and High-Speed Pulse Output Module → K. Logical channels 0~2 share Timer1 and 3~5 share Timer5; use the same frequency within each group. Output the 16-bit midpoint duty value 32768 on K channel 0. PWM() defaults to the 8-bit range 0~255; specifying true selects 0~65535.
void setup() {
  PWM_RESET();  // Stop PWM timers and reset their modes
  PWM(0, 32768, true);  // Output a midrange 16-bit duty value on K channel 0
}

void loop() {
}
Function example · set frequency/duty: FDPWM()
Function prototype
void FDPWM(uint8_t pin, int32_t intHz, float Duty);
The configuration is 1 K module, no Y module, and High-Speed Pulse Output Module → K. Logical channels 0~2 share Timer1 and 3~5 share Timer5; use the same frequency within each group. Output 1kHz at 50% duty on K channel 0. The core has no separate FPWM(); use FDPWM().
void setup() {
  PWM_RESET();  // Stop PWM timers and reset their modes
  FDPWM(0, 1000, 50.0f);  // Output 1kHz at 50% duty on K channel 0
}

void loop() {
}
Function example · output a specified pulse count: NPWM_BEGIN(), NPWM()
Function prototype
void NPWM_BEGIN(uint8_t pin, uint32_t intHz, float Duty, uint32_t N);
void NPWM(uint8_t pin);
The configuration is 1 K module, no Y module, and High-Speed Pulse Output Module → K. Logical channels 0~2 share Timer1 and 3~5 share Timer5; use the same frequency within each group. Output a single burst of 100 pulses at 1kHz and 50% duty on K channel 0. Call NPWM() on every loop() iteration without inserting delay().
void setup() {
  PWM_RESET();  // Stop PWM timers and reset their modes
  NPWM_BEGIN(0, 1000, 50.0f, 100);  // Prepare 100 pulses at 1kHz, 50% duty on K channel 0
}

void loop() {
  NPWM(0);  // Process the prepared pulse output and completion
}
Function example · stop/resume channel output: PWMOFF()
Function prototype
void PWMOFF(uint8_t pin, bool POff);
The configuration is 1 K module, no Y module, and High-Speed Pulse Output Module → K. Logical channels 0~2 share Timer1 and 3~5 share Timer5; use the same frequency within each group. Turn K channel 0 on for 2 seconds, then stop it for 2 seconds. After setting the PWMOFF() flag, call FDPWM() to apply the state and hold GPIO number 130 LOW. This stop flag does not apply to NPWM().
void setup() {
  PWM_RESET();  // Stop PWM timers and reset their modes
}

void loop() {
  PWMOFF(0, false);  // Clear the stop state of K channel 0
  FDPWM(0, 1000, 50.0f);  // Apply the cleared flag and start 1kHz, 50% output
  delay(2000);

  PWMOFF(0, true);  // Set the stop state of K channel 0
  FDPWM(0, 1000, 50.0f);  // Apply the stop flag and disconnect PWM output
  digitalWrite(130, LOW);
  delay(2000);
}
Function example · stop/reset PWM timers: PWM_RESET()
Function prototype
void PWM_RESET();
The configuration is 1 K module, no Y module, and High-Speed Pulse Output Module → K. Logical channels 0~2 share Timer1 and 3~5 share Timer5; use the same frequency within each group. Stop and reset Timer1·Timer5 in a K-only configuration. Output on channel 0 for 2 seconds, then stop. This affects all K outputs sharing the same timer.
void setup() {
  PWM_RESET();  // Stop PWM timers and reset their modes
  FDPWM(0, 1000, 50.0f);  // Output 1kHz at 50% duty on K channel 0
  delay(2000);
  PWM_RESET();  // Stop and reset all PWM on Timer1 and Timer5
  digitalWrite(130, LOW);
}

void loop() {
}
Status LED
Control the CPU module STATUS LED with LED_BUILTIN (D128).
Example program · status LED
Display the input 0 state on the CPU module STATUS LED (LED_BUILTIN, logical number 128).
void setup() {

}

void loop() {
  digitalWrite(LED_BUILTIN, digitalRead(0));
}
Development environment setup
- Connect the computer to the CPU module download port with a USB cable.
- Check the download port's COM number in Device Manager.
- Select the verified COM number under Tools → Port in Arduino IDE.
- Select
MPAINO-48A48R(T)under Tools → Board. - Click Verify (✓) in Arduino IDE. If there are no errors, click Upload (→) to transfer the program.
Dimensions
| Item | Dimensions |
|---|---|
| Product width | 190mm |
| Body height | 108mm |
| Overall height | Clip open: 120.42mm Clip closed: 115.16mm |
| Product depth | Body: 79mm Maximum with terminals: 83mm |
| Mounting hole spacing | 162mm |
| Mounting hole diameter | Ø4mm |
| DIN rail | 35mm |
| Front view | Side view |
|---|---|
 |  |
| Rear view | |
 |